Welcome to my Homepage! I’m Wang Meijun (王美军).👋
I am currently a Ph.D. student at the University of Science and Technology Beijing (USTB), under the supervision of Professor Yu Meng. I’m also a visiting Ph.D. student at Nanyang Technological University (NTU), College of Computing and Data Science (CCDS), under the supervision of Professor Ying He, supported by the CSC program.
My research interests lie in Human-Centric Intelligence and Autonomous Driving, with a particular focus on SMPL(-X)-based Pedestrian Pose Estimation and Prediction, as well as Text-to-Pose Generation.
Sharing, contributing, open-sourcing, and helping others are some of my greatest joys! Feel free to reach out to me anytime if you have any questions — Contact me here 💬.
🔥 News
- 2026.09: 🎉🎉🎉 Welcome to view my photography portfolio: 📷 Photo Gallery
📖 Education
- 2025.09 - Now, Ph.D. (Joint Program), College of Computing and Data Science (CCDS), Nanyang Technological University (NTU), Singapore.
- 2023.09 - Now, Ph.D., School of Mechanical Engineering, University of Science and Technology Beijing (USTB) , China.
- 2020.09 - 2023.06, M.S., School of Mechanical Engineering, University of Science and Technology Beijing (USTB) , China.
- 2016.09 - 2020.06, B.S., School of Mechanical Engineering, University of Science and Technology Beijing (USTB) , China.
📝 Publications
- You can find my all publications on [Google Scholar].
- You can find my all projects on [Github].
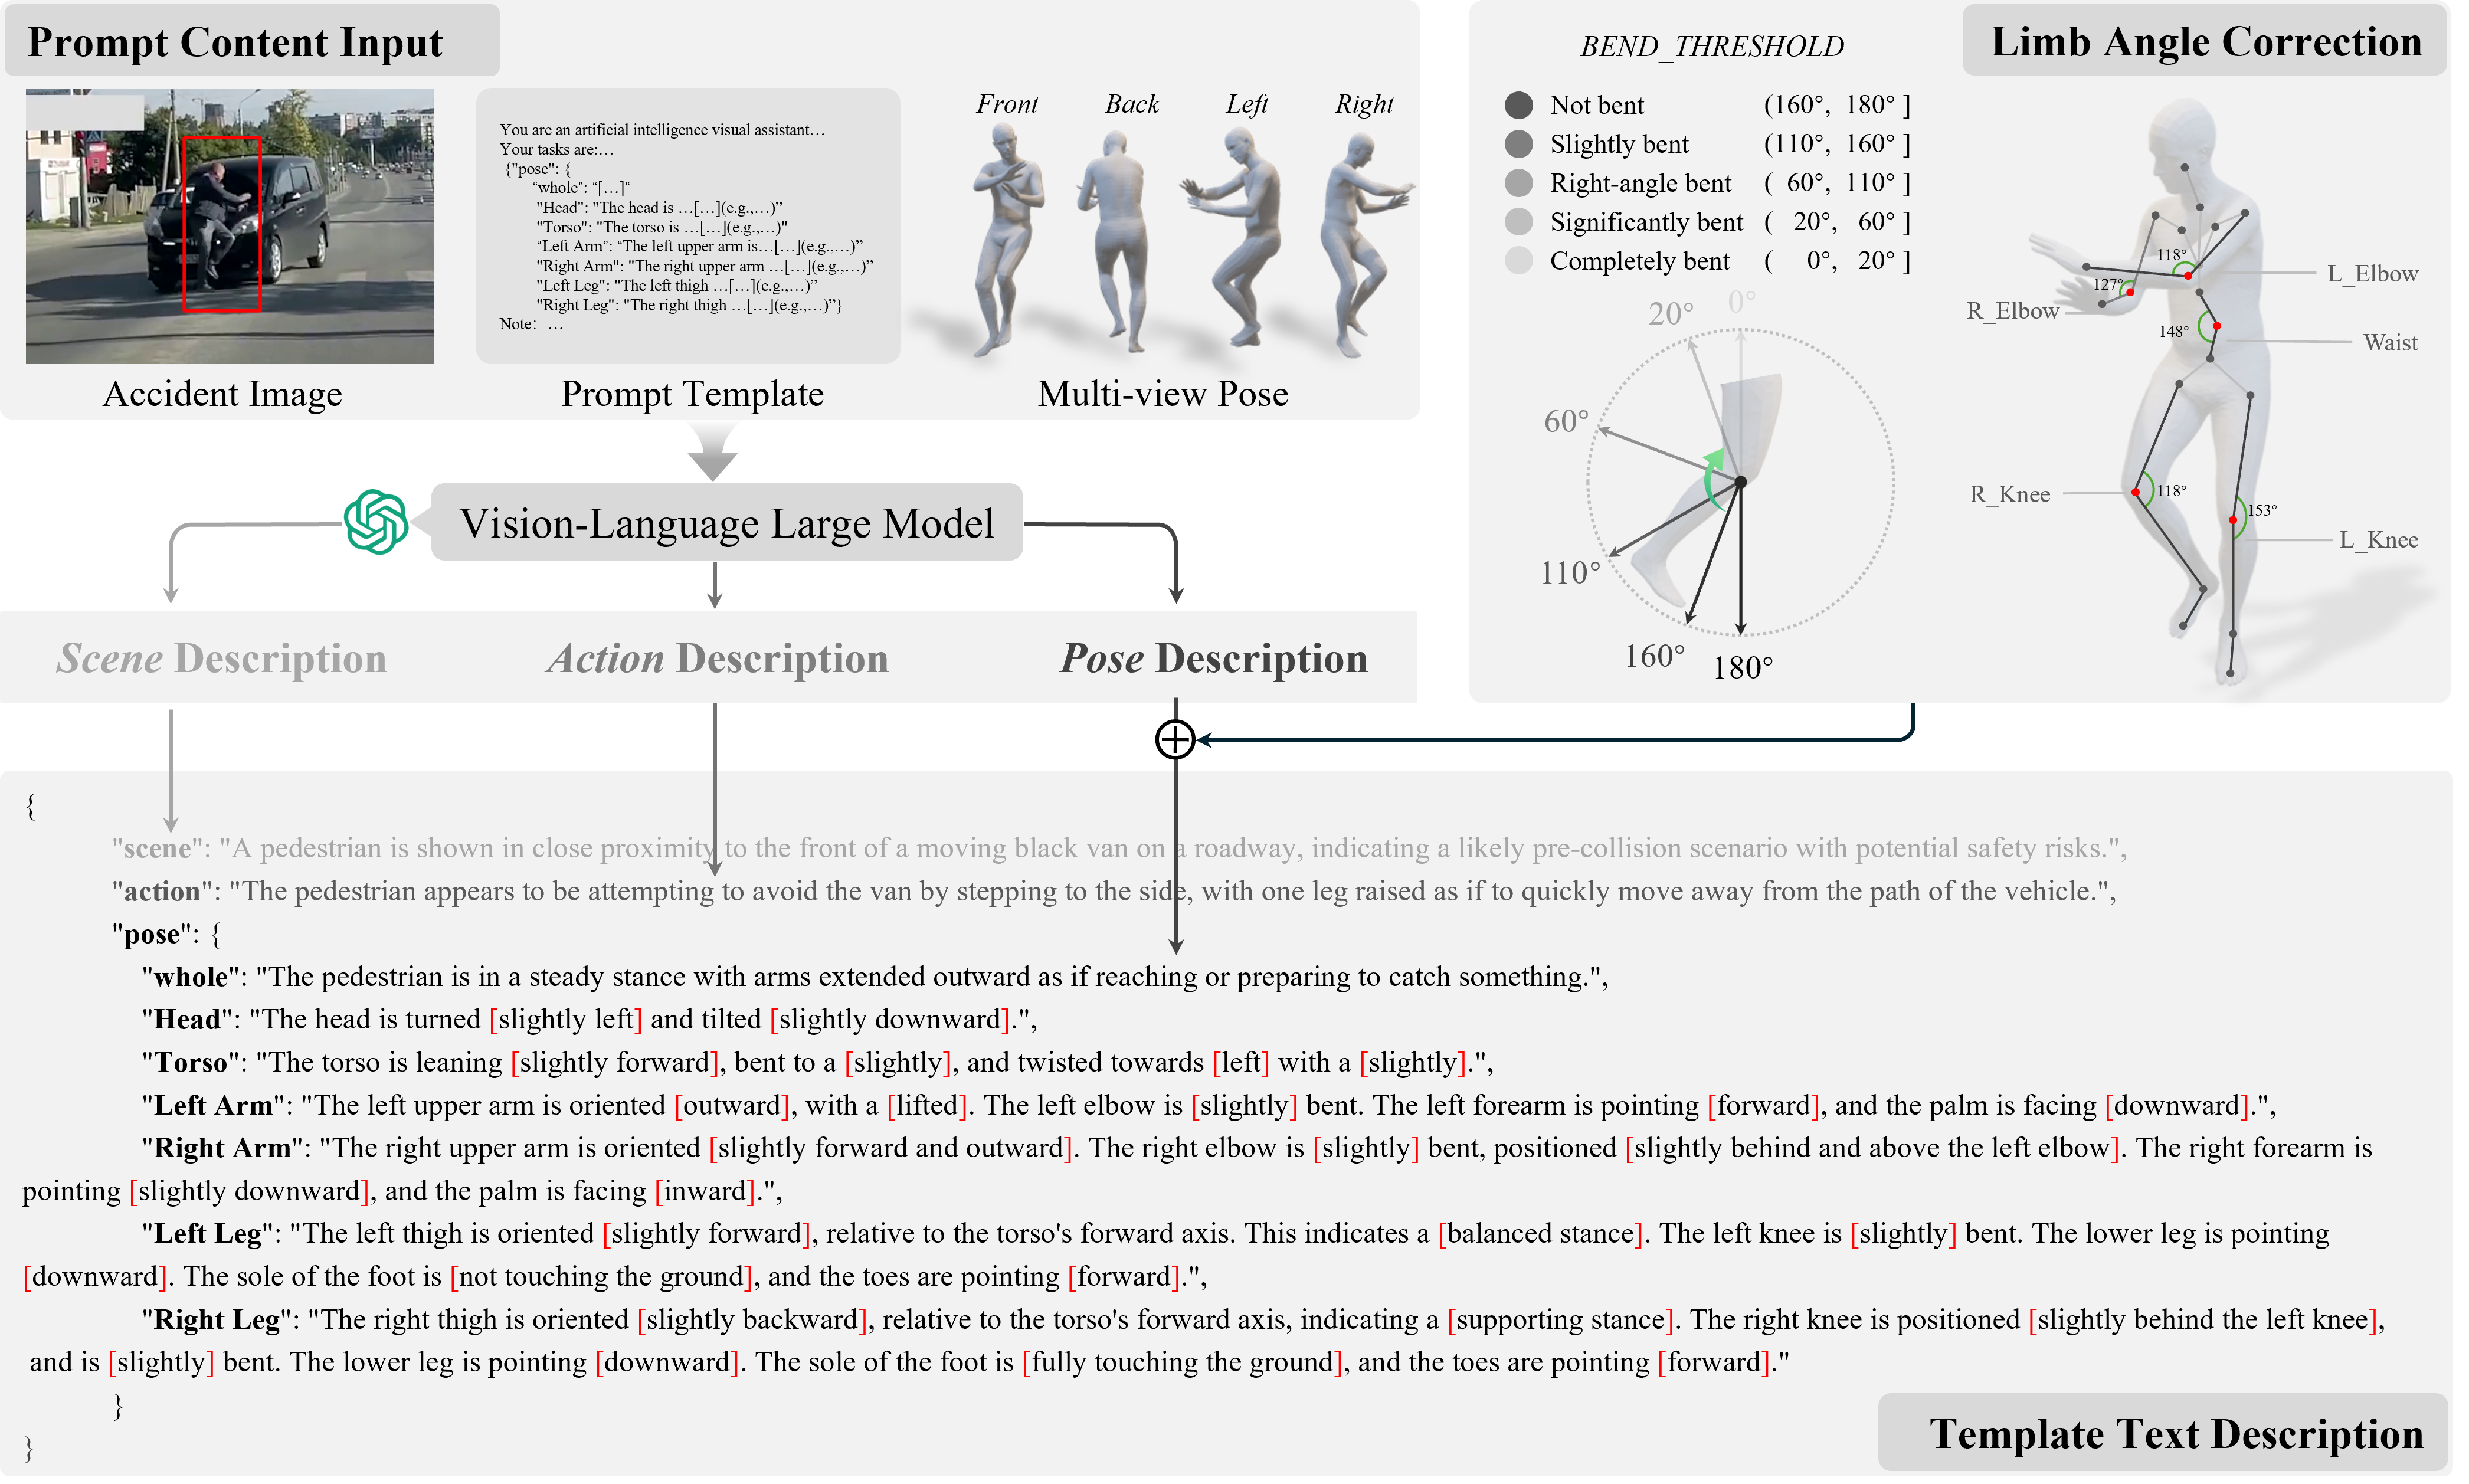
Pedestrian Pre-Collision Pose Generation from Eyewitness Descriptions Without Visual Evidence
Meijun Wang, Yu Meng*, Chao Zheng, Xiaorui Peng, Guangxuan Song, Zhongwei Qiu, Ying He
- We construct PVCP2, a large-scale text-pose dataset with over 10K fine-grained pedestrian pre-collision text-pose pairs generated through VLM-assisted annotation and template-based refinement.
- We propose PPSG, a probabilistic framework that generates diverse and plausible SMPL-based 3D pre-collision poses from structured eyewitness descriptions without relying on visual evidence.
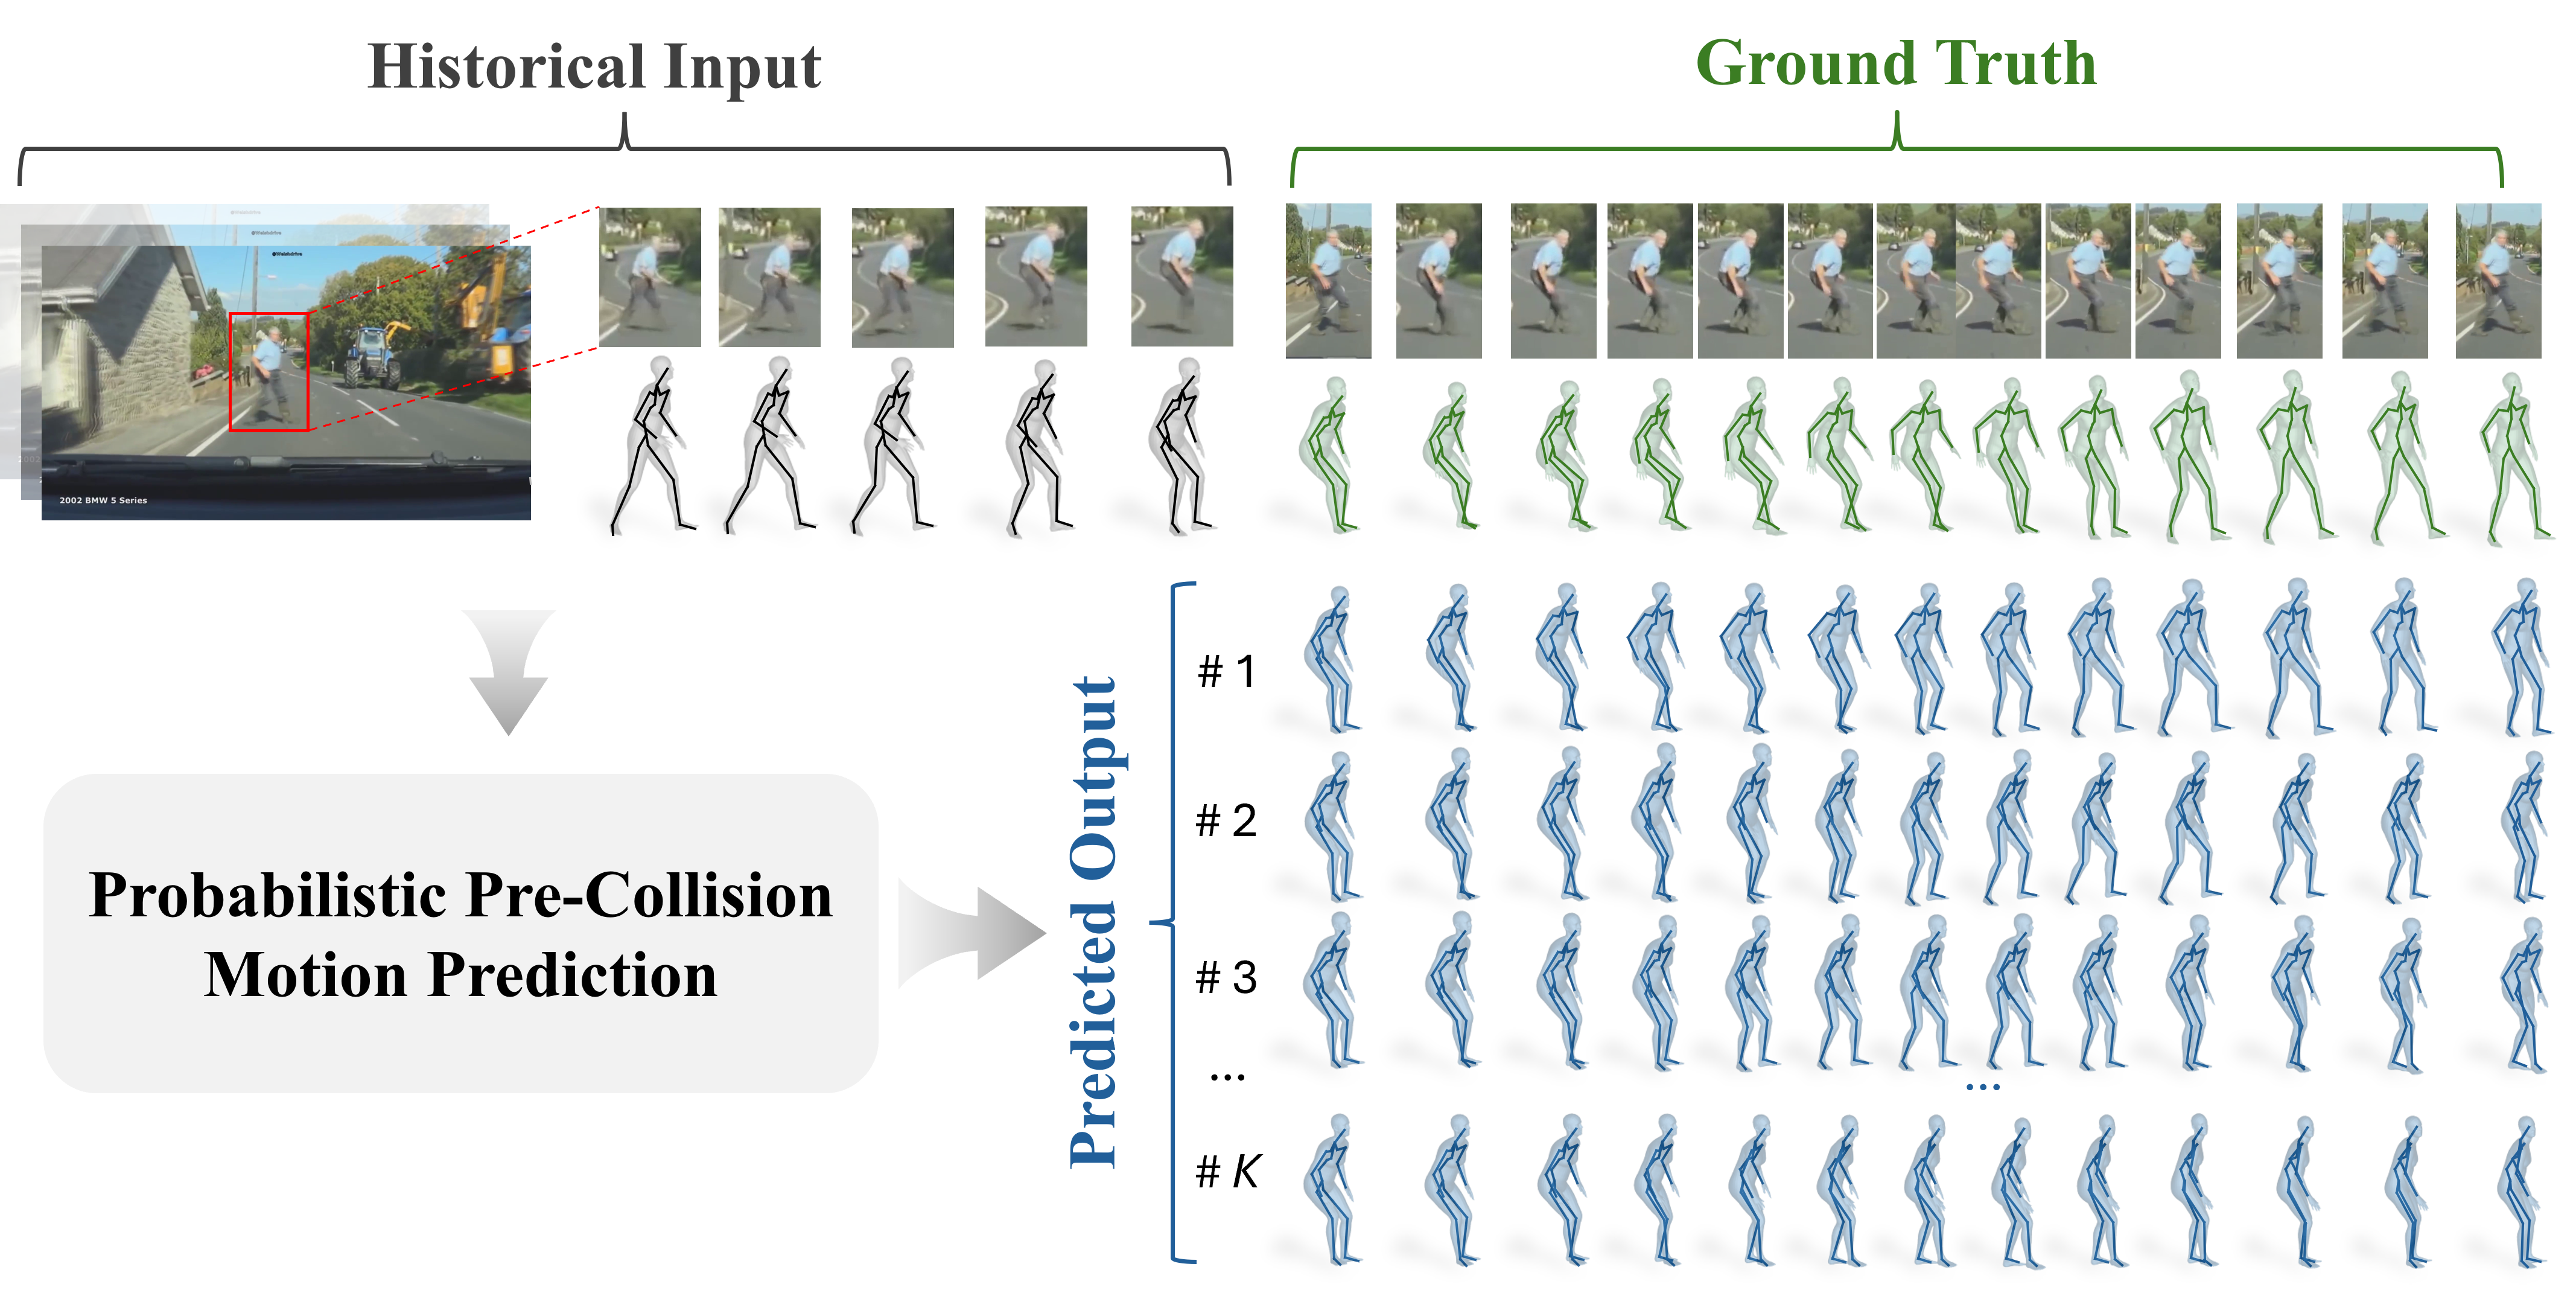
Scene Semantics-Guided Probabilistic 3D Pedestrian Motion Prediction in Pre-Collision Scenarios
Meijun Wang, Yu Meng*, Ying He, Chao Zheng, Xiaorui Peng, Shaofei Shan, Huangjian Xu
- We construct PVCPM, a benchmark containing 172 temporally refined 3D pedestrian motion sequences from 159 real dashcam pre-collision scenes, and reveal its distinctive mid- and high-frequency dynamics.
- We propose a scene semantics-guided two-stage CVAE with VLM-derived traffic cues and a FiLM-Guided Auxiliary Sampler to generate diverse, scene-consistent pre-collision motions.

Pedestrian-Centric 3D Pre-collision Pose and Shape Estimation from Dashcam Perspective
MeiJun Wang, Yu Meng*, Zhongwei Qiu, Chao Zheng, Yan Xu, Pengxiaorui, Jian Gao
[Paper] · [Code]

- We constructed a pedestrian pre-collision pose dataset, PVCP, by collecting dashcam videos of pedestrian-vehicle collisions. (With a SMPL-annotation-tools)
- We propose a two-stage pedestrian pre-collision pose and shape estimation network, PPSENet.

MeiJun Wang, Yu Meng*, Yan Xu, Quan Li, Bingbing Nie

- We build a pedestrian-vehicle collision video dataset, annotated by camera viewpoints for case analysis and posture research.
- We propose a real-time vision-based pipeline to reconstruct pre-impact multi-body postures from real accident images.
-
Chao Zheng, Yan XU, Xiaorui Peng, Meijun Wang, Yu Meng
EAAI 2026 Engineering Applications of Artificial Intelligence
-
Monoafkd: Align and Frequency Cross Knowledge Distillation for Monocular 3d Object Detection
Xiaorui Peng, Yu Meng, Chao Zheng, Meijun Wang
KBS 2025 Knowledge-Based Systems
-
Xiaorui Peng, Yu Meng; Boqiang Shi, Chao Zheng, Meijun, Wang
EAAI 2025 Engineering Applications of Artificial Intelligence
-
Few-shot Point Cloud Semantic Segmentation via Support-Query Feature Interaction
Chao Zheng, Li Liu, Yu Meng, Xiaorui Peng, Meijun Wang
TCSVT 2024 IEEE Transactions on Circuits and Systems for Video Technology
-
Passable area segmentation for open-pit mine road from vehicle perspective
Chao Zheng, Li Liu, Yu Meng, Meijun Wang, Xianyao Jiang
EAAI 2024 Engineering Applications of Artificial Intelligence
👨💼 Work Experience
- 2023.03 - 2023.09, Algorithm Intern @ Lenovo Research
- Multi-view, Camera calibration
- MANO, Hand pose estimation, Dataset,
🎖 Honors and Awards
- 2025, Rui’er Foundation Scholarship
- 2023, Outstanding Graduate, University of Science and Technology Beijing (USTB)
- 2022, National Graduate Scholarship (Master’s)
- 2022, Contribution Award, China Intelligent and Connected Vehicles Algorithm Competition (CIAC), Perception Track
- 2021, Awarded the Gold Prize, the 5th “Three Minute Thesis” Academic Speech Competition, USTB
- 2020, First Prize, International Contest of innovAtioN (iCAN), Calmspoon Stabilizing Tableware
- 2020, Gold Award, “Challenge Cup” Capital College Student Entrepreneurship Competition, Calmspoon Stabilizing Tableware (“挑战杯”省赛金奖)
🧾 Patents
- 2026, A Witness-Description-Based Method for Generating Pedestrian Pre-collision Pose (一种基于目击者描述的行人应急姿态生成方法 ), Pending, 202610492569.7
- 2022, A Vision-Based Method for Multi-Rigid-Body Pedestrian Pose Reconstruction (一种基于视觉的多刚体行人模型姿态重建方法), Granted, 202111459545.5
- 2020, Electronic Anti-Shake Tableware (一种电子防抖餐具), Granted, CN201910912611.6
- 2019, A Human-Weight-Driven Trash Bin for Compression and Solid-Liquid Separation (一种以人体重力驱动的压缩及固液分离垃圾箱), Granted, CN201910679971.6
💬 Academic Service
- Journal and Conference Reviewer: NeurIPS·2025, TCSVT, TITS, EAAI
🔗 Links
I am fortunate to collaborate closely with the following research partners:
-
Zhongwei Qiu. My partner working on human-centric visual perception, multimodal learning, and generative models with applications in healthcare and science.
-
Guangxuan Song. My partner working on knowledge graphs and large language models, particularly in their application to scientific data analysis in materials science.
-
Xin Qin. My partner working on industrial process fault diagnosis and optimization.
In addition, I occasionally share text and video content on social media platforms.
-
Welcome to my video sharing: 陌尘小小-BiliBili.
-
Welcome to my read sharing: 陌尘小小-Zhihu.
- Recommended Reading: